Your cart is empty
 Short Rigid Couplings
 Controlflex Couplings
 Jaw Couplings
 Oldham Couplings
 Bearing Locknuts – TCN
 Double Wide Shaft Collars
 Heavy Duty Shaft Collars
 International Series Shaft Collars
 Keyed Shaft Collars
 Mountable Shaft Collars
 Quick Clamping Shaft Collars
 Set Screw Shaft Collars
 Thin Line Shaft Collars
 Threaded Shaft Collars – Pacific International Bearing Products
 Two-Piece Shaft Collars
 Friction Bearing Universal Joints
 Needle Bearing Universal Joints
Robotics
Bearings Used in Surgical and Rehabilitation Robots
02 October, 2026
22 min read
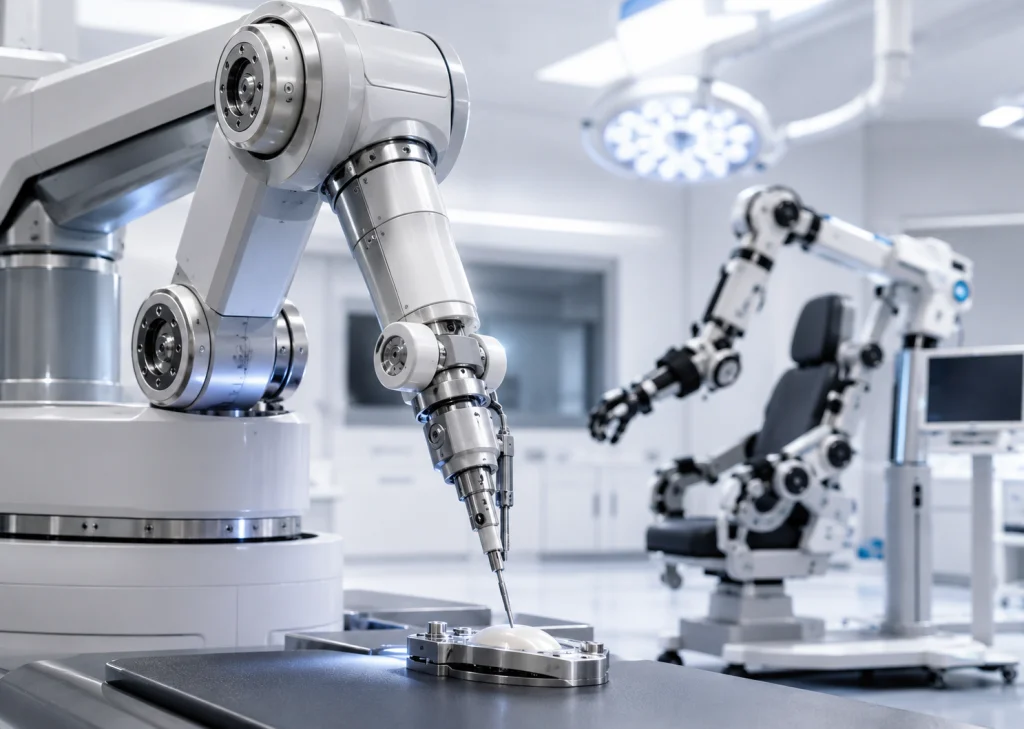
Bearings in surgical and rehabilitation robots do more than reduce friction. They help define how smoothly a joint starts moving, how accurately it stops, how much play develops under load, and how consistently the mechanism feels after thousands of reversals. In a surgical arm, those details affect positioning and tool control. In a rehabilitation robot or powered orthosis, they also affect how naturally the mechanism follows or assists a patient’s movement.
Pacific International Bearing Sales (PIB) works with precision bearing applications where compact packaging, repeatability, load handling, torque, contamination control, and maintenance all have to be considered together. Medical robotics will need bearings in the base, shoulder, wrist, instrument drive, linear stage, and patient-interface joints can all having different bearing behavior.
The practical goal is simple: choose a bearing arrangement that supports the real load path and motion profile without adding unnecessary friction, lost motion, weight, or maintenance. That usually means looking beyond bore and outside diameter and treating the bearing as part of the robot’s motion system.
Key Takeaways
Crossed roller bearings are strong candidates for compact rotary joints that need high rigidity while carrying radial, axial, and moment loads at the same time.
Thin-section and four-point contact bearings help when a joint needs a large bore for cables, tubing, sensors, or drive components but cannot accept a bulky bearing cross-section.
Angular contact bearing pairs are useful where preload, axial location, and shaft stiffness need to be controlled deliberately.
Miniature deep-groove bearings fit motors, pulleys, instrument drives, encoders, and small pivots where low friction, low noise, and compact size matter.
Linear guides and precision linear bearings become part of the accuracy system in robot carriages, positioning stages, therapy devices, and other straight-line axes.
For medical robotics, sealing, corrosion resistance, lubricant choice, cleaning exposure, torque, and installation quality can matter as much as nominal load capacity.
Where Bearings Work in Medical Robots
Surgical and rehabilitation robots use bearings anywhere one component must rotate, pivot, articulate, or travel in a straight line while holding alignment. The exact architecture varies widely, but the bearing duties are familiar: support the joint, control deflection, minimize friction, and keep motion repeatable as load direction changes.
In a multi-axis surgical robot, the larger arm joints may see combined radial, axial, and overturning loads while a wrist or instrument mechanism operates in a much smaller envelope. A rehabilitation robot can have a similar mix, but the load profile may include patient weight, gait reversals, repeated flexion and extension, and occasional shock from foot contact or an abrupt change in motion.
That is why the same robot may use crossed roller bearings in one axis, angular contact bearings in another, miniature ball bearings in a distal mechanism, and linear guides on a carriage or positioning stage. Bearing selection follows the duty of the joint, not the product category of the robot.
| Robot location | Typical bearing family | What matters most |
| Base, shoulder, elbow, or major rotary joint | Crossed roller; thin-section; angular contact arrangement | Rigidity, combined-load support, moment capacity, low play, compact packaging |
| Wrist or hollow rotary joint | Thin-section; four-point contact; crossed roller | Large bore, low section height, cable routing, torque, running accuracy |
| Servo, reducer, or instrument drive shaft | Angular contact pair; deep-groove; miniature bearing | Axial location, preload, speed, low noise, low torque |
| Small pulley, encoder, idler, or distal mechanism | Miniature deep-groove ball bearing | Compact size, low friction, low noise, contamination control |
| Linear positioning or therapy axis | Profile rail guide; linear ball guide; cross-roller guide | Straightness, rigidity, smooth travel, moment-load support, service access |
| Alignment linkage or articulated secondary joint | Spherical plain bearing; rod end | Misalignment capability, oscillation, wear, low binding |
How Surgical and Rehabilitation Robots Differ
Both types of robots need smooth, controlled motion, but they do not ask exactly the same thing from the bearing system.
Surgical robots place a high premium on positional stability, low lost motion, compact packaging, quiet operation, and predictable torque. Small unwanted movement at a joint can become a larger error at the tool tip, especially when several axes stack together. A stiff bearing arrangement with controlled clearance helps the servo system hold position instead of correcting around mechanical compliance.
Rehabilitation robots add another requirement: the machine interacts continuously with a person who is moving. Exoskeleton joints, powered orthoses, gait trainers, and therapy arms often reverse direction repeatedly and may need low passive resistance so the mechanism does not feel heavy or sticky. Bearings are only one part of backdrivability, but excess bearing torque or seal drag can add directly to the resistance the patient and actuator feel.
The difference changes selection priorities. A highly preloaded joint may feel excellent on a rigidity calculation but create too much torque for a human-interaction axis. A lightly loaded low-friction bearing may feel smooth but allow more deflection or play than a surgical positioning joint can tolerate. The correct choice balances stiffness, torque, load, packaging, and service environment for the actual axis.
Bearing Types Commonly Considered
Crossed roller bearings for rigid rotary joints
Crossed roller bearings use cylindrical rollers arranged at right angles to one another. That geometry allows one compact bearing to carry radial, axial, and moment loads together. The result is high rigidity and good rotational accuracy in a relatively small axial space.
This makes crossed roller bearings a natural candidate for robot bases, shoulder joints, rotary positioning axes, and other locations where a wide joint must remain stiff under an off-center load. In surgical equipment, they can help keep a manipulator or positioning stage from rocking under changing tool loads. In rehabilitation systems, they can be useful at larger joints where the structure must support load without a bulky two-bearing stack.
The tradeoff is that crossed roller bearings are sensitive to mounting accuracy, preload, and housing stiffness. A distorted ring or excessive preload can raise torque and reduce the smooth feel the robot needs.
Thin-section and four-point contact bearings for tight packaging
Thin-section bearings are useful when the joint diameter needs to stay large while the radial cross-section must remain small. That is common in robotic joints that route cables, pneumatic lines, wiring, sensors, or drive elements through a hollow center.
Four-point contact versions can support combined loads in a compact package and may replace more complex bearing stacks in the right application. Thin-section angular contact arrangements are another option when axial stiffness and preload need tighter control.
The design advantage is packaging. The engineering caution is ring stiffness. Thin rings can be affected by housing roundness, fit, clamp load, and structural deflection, so the installed condition matters as much as the bearing catalog description.
Angular contact bearings for controlled axial location and preload
Angular contact ball bearings support radial load together with axial load in one direction, so they are commonly used in pairs when a shaft must be located axially in both directions. Back-to-back, face-to-face, and tandem arrangements each change how the set handles moment load, misalignment, and thrust.
In medical robots, angular contact pairs can fit servo shafts, reducers, spindle-like instrument drives, compact rotary stages, and other axes where stiffness must be tuned with preload. The benefit is control. The risk is over-preload: more preload can reduce play and increase rigidity, but it also raises friction torque and heat.
Miniature and deep-groove ball bearings for small rotating components
Miniature deep-groove ball bearings are practical in small motors, encoders, pulleys, idlers, cable-routing hardware, instrument drive mechanisms, and compact secondary pivots. Their basic strengths are low friction, simple packaging, and the ability to support radial load with moderate axial load in both directions.
For small mechanisms, noise and torque often matter more than engineers expect. A bearing that is oversized, heavily sealed, poorly lubricated, or distorted by fit can make a small actuator feel rough even when the load rating is generous.
Linear guides and precision linear bearings for straight-line axes
Not every robot axis rotates. Surgical carts, instrument positioning stages, therapy tables, gait trainers, and rehabilitation carriages can all use linear motion. In these assemblies, the guide is part of the positioning system because it controls friction, straightness, stiffness, and resistance to off-center loads.
Profile rail guides are useful for longer strokes and robust carriage support. Cross-roller guides are attractive for finite-stroke precision mechanisms where high rigidity and smooth motion are needed in a compact package. The correct choice depends on stroke, load direction, moment load, accuracy, contamination, and how the rail is mounted.
Spherical plain bearings and rod ends for intentional misalignment
Some rehabilitation linkages and secondary robot joints need angular misalignment rather than maximum rotational accuracy. Spherical plain bearings and rod ends can accommodate that articulation while transferring load through a compact joint.
They are useful when bracket alignment changes through the stroke or when the structure cannot remain perfectly coaxial under load. They are not usually the first choice for the primary precision axis of a surgical manipulator, because the design priority there is typically stiffness and repeatability rather than misalignment capacity.
What Happens When the Bearing Is Wrong
The wrong bearing rarely fails in a dramatic way on day one. More often, the robot starts losing the qualities the design depends on. A joint takes more motor current to start moving. A direction reversal feels sticky. Positioning corrections increase. Noise rises. Free play becomes measurable. A therapy axis that should feel transparent to the patient starts feeling heavier or less consistent.
Those symptoms can come from the bearing type, but they can also come from preload, fit, lubrication, sealing, housing stiffness, or contamination. That is why replacing a bearing with the same size does not always solve the underlying problem.
With the correct bearing and installation, the improvement is usually easy to recognize: motion starts more consistently, the joint stays rigid under load, direction changes are cleaner, torque is more predictable, and the control system spends less effort correcting mechanical behavior. The benefit shows up in repeatability and maintenance as much as it does in bearing life.
| If the bearing choice is wrong | What you may see | What improves with the right choice |
| Too much clearance or weak joint support | Lost motion, tool-point movement, inconsistent reversals | Better repeatability and a more stable control path |
| Too much preload or seal drag | High motor current, sticky starts, heat, poor backdrivability | Lower and more predictable torque |
| Bearing family cannot handle moment load | Rocking, uneven load sharing, accelerated wear | Higher joint rigidity and cleaner load transfer |
| Poor fit or distorted housing | Noise, rising torque, uneven raceway loading | Smoother running and more predictable wear |
| Insufficient environmental protection | Contamination, corrosion, lubricant loss or degradation | More stable performance and fewer maintenance surprises |
| Lubricant or material does not match cleaning exposure | Torque change, corrosion, seal or lubricant problems | Better compatibility with the actual service environment |
The Selection Factors That Matter Most
1. Define the actual load path
Start with what the bearing sees, not only what the robot carries. Tool offset, arm length, patient force, gravity, acceleration, reducer output, bracket stiffness, and joint spacing all change the radial, axial, and moment loads at the bearing. A compact wrist bearing can see a large overturning moment even when the payload is modest.
2. Separate rigidity from load capacity
A bearing can have enough load capacity and still allow too much deflection for a precision joint. Surgical positioning axes often care about stiffness because small angular movement at the joint is multiplied at the tool tip. Rehabilitation joints also need stiffness, but excessive stiffness created through preload can raise torque and reduce the natural feel of the mechanism.
3. Set limits for torque and free play
Breakaway torque, running torque, seal drag, lubricant viscosity, and internal clearance all influence how an axis feels and how much actuator force it needs. Free play affects lost motion and reversal accuracy. These values should be considered as system requirements, not discovered after the first prototype is assembled.
4. Use preload carefully
Preload can improve rigidity, running accuracy, and control of play. Too much preload increases friction and heat and can reduce life. In a small robot joint, the wrong preload can consume a surprising portion of the available motor torque. The housing, shaft, bearing fit, and thermal condition all affect the preload that exists after assembly.
5. Treat the housing as part of the bearing
Precision bearings cannot correct a distorted mount. Thin-section rings are especially sensitive to out-of-round housings and uneven clamp loads, while crossed roller bearings need flat, rigid mounting surfaces to preserve their intended geometry. Installation tolerances, shoulder squareness, fastener pattern, and structural stiffness should be developed with the bearing selection.
6. Match sealing and lubricant to the environment
Seals help retain lubricant and keep contaminants out, but contact seals add drag. Open or shielded bearings can run with lower torque in protected internal joints, while exposed joints may need more protection. Cleaning chemicals, moisture, corrosion risk, temperature, and lubricant compatibility should all be checked for the actual machine.
Sterilization deserves special care. Many major robot joints never enter the sterile field, while some reusable instruments or exposed mechanisms may be subjected to validated cleaning or sterilization processes. If a bearing will see those processes, the materials, lubricant, seals, and retention method must be selected and validated for that specific exposure rather than assumed to be compatible.
7. Consider noise and vibration as engineering signals
Quiet operation matters in clinical environments, but noise is also useful feedback. Rising bearing noise can indicate contamination, preload change, raceway damage, lubrication issues, or fit problems. In a rehabilitation device, vibration that reaches the patient can also affect perceived smoothness even when the axis is still meeting its positioning target.
8. Design for service access and total cost
A lower-cost bearing is not a lower-cost choice if replacement requires removing a robot arm, re-aligning an axis, re-routing cables, or repeating calibration. Sealed-for-life designs can reduce maintenance in some locations, while serviceable arrangements may make more sense in accessible high-duty joints. The right answer depends on duty cycle, access, contamination, and the expected maintenance plan.
Surgical Robot Bearing Priorities
For surgical robots, the strongest selection questions usually revolve around rigidity, low and stable torque, compact size, low play, and predictable behavior over repeated movements. Bearings support the mechanical side of accuracy; encoders and software cannot fully compensate for a joint that deflects, sticks, or develops variable friction.
The farther a joint is from the tool tip, the more its angular error can influence the final position. That does not mean every surgical axis needs the highest possible preload or the stiffest possible bearing. It means the bearing arrangement should be sized and mounted around the required accuracy, load, torque, and envelope of that axis.
Cleaning and contamination strategy also needs to follow the robot architecture. Internal arm bearings may live in a protected housing, while instrument-side mechanisms can face much more demanding cleaning or sterilization requirements. Treating those locations as the same environment can lead either to unnecessary drag or insufficient protection.
Rehabilitation Robot Bearing Priorities
Rehabilitation robots often operate at lower speeds than industrial robots, but the motion is highly repetitive and frequently reverses direction. Human interaction also makes friction more noticeable. In an exoskeleton knee or elbow, a small increase in parasitic torque can change how naturally the mechanism follows the patient.
Joint alignment is another practical issue. Human anatomy does not behave like a perfect single-axis hinge, and patient dimensions vary. Some rehabilitation mechanisms use linkages, compliant elements, or alignment joints to accommodate that variation. Bearing selection has to support the intended motion without introducing binding, edge loading, or excessive play.
Loads can also be less predictable than a fixed industrial cycle. A gait device can see changes in patient contribution, speed, support force, and impact. That makes stiffness, shock tolerance, corrosion resistance, and maintenance access important even when average speed is low.
A Practical Bearing Selection Process
A good medical robot bearing review starts before the part number. Define the joint, the load path, the motion, and the maintenance environment first. Then compare bearing families against those requirements.
For PIB, the most useful application information includes the shaft and housing envelope, radial and axial loads, overturning moment, speed or oscillation range, duty cycle, allowable torque, free-play or stiffness target, misalignment, temperature, contamination exposure, cleaning process, lubricant preference, and expected service access.
That information makes it much easier to decide whether the joint wants a crossed roller bearing, a thin-section bearing, an angular contact pair, a miniature ball bearing, a linear guide, or a misalignment-capable joint. It also reduces the chance of solving an assembly problem later with extra motor torque, software compensation, or premature bearing replacement.
Frequently Asked Questions
What bearings are commonly used in surgical robots?
Typical bearing types include crossed roller bearings for rigid rotary joints, thin-section and four-point contact bearings for large-bore compact joints, angular contact pairs for controlled shaft support, miniature deep-groove bearings for small drives and pivots, and linear guides for straight-line positioning. The correct choice depends on the specific axis and load path.
Why are crossed roller bearings useful in medical robots?
Their crossed-roller geometry lets one compact bearing support radial, axial, and moment loads while providing high rigidity and good rotational accuracy. That combination is useful in rotary joints and positioning stages where space is limited and deflection must be controlled.
Are thin-section bearings a good choice for robot joints?
They can be. Thin-section bearings are useful when the joint needs a large diameter or hollow bore without a large radial cross-section. They help with cable and tubing routing, but the housing and mounting structure must be stiff and round enough to avoid distorting the thin bearing rings.
How do bearings affect rehabilitation robot feel?
Bearing friction, seal drag, preload, and alignment all contribute to the passive resistance of the joint. In a human-interaction robot, excessive bearing torque can make reversals feel sticky or increase the force the actuator must produce. The bearing is only one part of system backdrivability, but it is an important one.
Do bearings in surgical robots need to be sterilizable?
Not automatically. Many robot arm bearings remain inside protected housings and never enter the sterile field. Bearings in reusable instruments or exposed mechanisms may face validated cleaning or sterilization processes. In those cases, material, lubricant, seal, and retention choices must be checked for the exact process.
Is more preload always better for robot accuracy?
No. Preload can improve stiffness and reduce play, but excessive preload increases friction, heat, and bearing stress. The right preload is the amount needed to meet stiffness and running-accuracy requirements without creating unnecessary torque or shortening service life.
What information does PIB need to help select a medical robot bearing?
The most useful inputs are the bearing location, envelope, load directions and magnitudes, moment load, motion profile, speed or oscillation angle, duty cycle, allowable torque, stiffness or play target, misalignment, environment, cleaning exposure, lubrication preference, and service requirements.
Final Thoughts
Bearings used in surgical and rehabilitation robots are small components with a direct influence on how the machine moves and how predictable that motion stays. The right selection is built around the real joint: load direction, moment load, stiffness, torque, free play, packaging, cleaning exposure, lubrication, and maintenance access.
When those details are defined early, the bearing becomes a stable part of the motion system. PIB can help review crossed roller, thin-section, angular contact, miniature, linear-motion, spherical, and rod-end bearing options for medical robotics applications and narrow the selection around the actual mechanism.
Contact us at 1(800) 228-8895 or visit our website at www.pibsales.com.